
Introduction
I remember this: a rainy afternoon in my tiny workshop, a song stuck in my head, and a busted craftsman’s cart that refused to move—until I fiddled with its motor. That little moment taught me more than any manual did. In projects and product tests I see the same numbers replaying: over 40% of small vehicle failures trace back to mismatch and misread specs, and the data keeps nudging me—what if we chose differently?
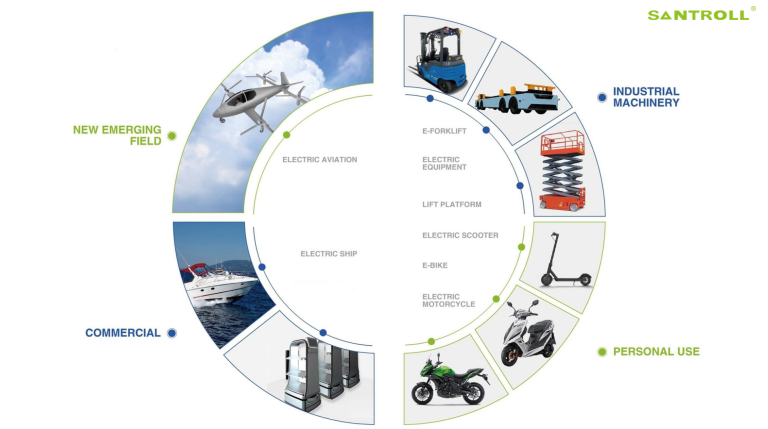
The electric motor sits at the heartbeat of so many designs, from scooters to studio rigs; it’s not just metal and magnets, it’s voice and muscle—and that voice can be tuned. (Yes, I’m that person who listens to a motor hum and hears promises.) I’ll share practical angles and honest opinions—some will surprise you, some will annoy you—but all born from hands-on work and late-night troubleshooting. Ready to rethink what you thought you knew? Let’s move on to where the real trouble hides.
Part 2 — Where the Problems Lurk: Flaws in Traditional Solutions
Technical first: when teams pick a pmsm motor as a default, they often treat it like a drop-in improvement. They see “permanent magnet,” think efficiency, and tick the box. But real systems have layers—inverter sizing, thermal limits, and control loops all matter. I’ve watched projects stall because the inverter couldn’t handle short bursts of current; the rotor overheated; the encoder lost position during vibration. These aren’t rare—they’re predictable if you look for them.
Here’s a blunt take: traditional specs focus on peak power and ignore duty cycle and torque ripple. Torque ripple, commutation strategy, and field-weakening range get buried in datasheets or glossed over in meetings. Look, it’s simpler than you think—if you test under real loads, anomalies show fast. We’ve had motors that passed bench tests but failed on the road due to sustained high torque and poor cooling. In my view, the old approach that emphasizes single-number metrics is a design shortcut that costs time and reputation. Also—funny how that works, right?—the teams who model thermal flow and transient response early save weeks later.
Why do these mismatches keep happening?
Mostly because decisions are made in isolation: chassis folks, controls folks, and procurement don’t always talk about the same problems. Add in assumptions about back-EMF, inverter headroom, and shaft loading, and you’ve got a recipe for surprises. I recommend early integrated tests—spin the motor with expected torque profiles, record temperature rise, and confirm encoder fidelity under vibration. You’ll thank me later.
Part 3 — Looking Ahead: Better Choices and Practical Metrics
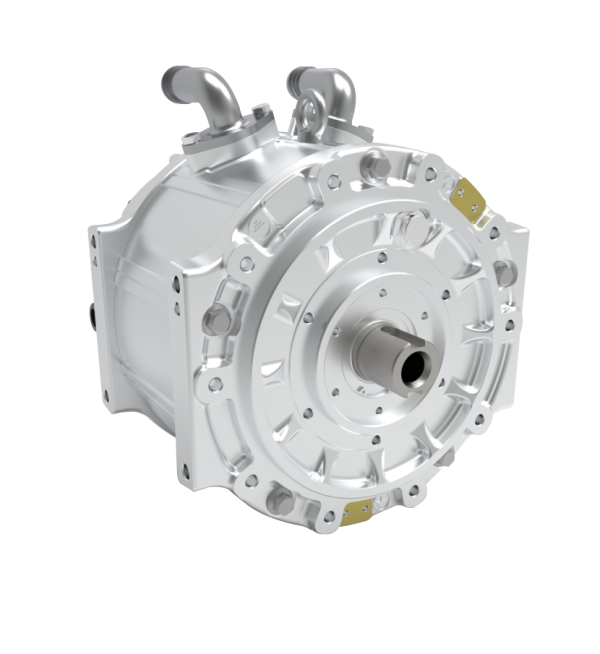
Now let’s pivot to future-facing fixes. I prefer a comparative approach: match system-level needs to motor features, don’t reverse-engineer the other way. New practice favors control-aware hardware—controllers that adapt to changing loads, better thermal designs, and smarter power converters that protect the system. For watercraft, for instance, selecting electric boat motors that pair with torque-limited controllers reduces stall risk and extends battery life. We’re seeing real gains when teams think beyond horsepower and include continuous duty, transient handling, and cooling pathways.
Case example: a small electric launch we worked on swapped to a motor with a wider field-weakening band and a slightly higher torque at low RPM. The result was smoother acceleration, less battery drain, and fewer thermal trips. I like to point to that project because it shows how modest swaps in motor characteristics—combined with matched inverter tuning—change user experience for the better. Short pause—this is not theoretical; it’s what we measured over three months of sea trials.
What’s Next — How to Decide
In practice, I advise three clear evaluation metrics when you judge motors and systems. First, look at continuous torque rating under realistic cooling—not just the brief peak specs. Second, check control compatibility: can your inverter handle regenerative bursts, and does the controller support the necessary commutation scheme? Third, validate thermal and mechanical resilience: test under vibration, elevated ambient temps, and full-load duty cycles. These metrics are practical; they uncover hidden pain points before you buy. — I say this from hands-on cost and time savings.
To wrap up: pick with the system in mind, test under honest conditions, and don’t be seduced by a single big number. Measurement beats faith. If you want a solid place to start, look at vendors who provide test data and real-world references. I’ve found that working with suppliers who share thorough performance curves and deployment stories—like those from Santroll—saves headaches and keeps projects singing.