
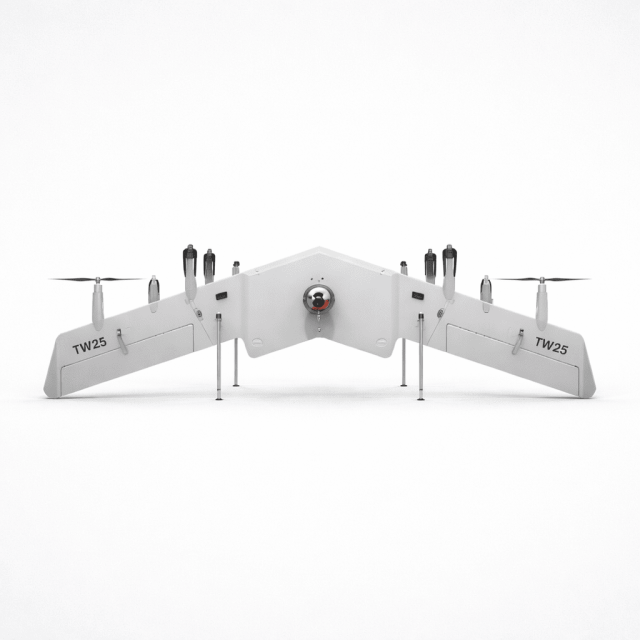
How sensor fusion reshapes mission trade-offs
Design teams comparing small tactical platforms now place EO/IR sensor fusion at the center of capability trade-offs. For units deciding between vertical lift and range, a vtol fixed wing drone often represents the compromise: hover for launch and recovery, fixed-wing for loiter and range. Fusion of electro-optical and infrared streams with short-range radar changes what commanders can expect from a single sortie—better target discrimination, longer effective surveillance windows, and more robust tracking in low light. The recent operational emphasis on persistent ISR in the Ukraine conflict has made these benefits visible at scale, influencing procurement and tactics.

Side-by-side: airframe, payload, and sensor architecture
When comparing platforms, three dimensions dominate: airframe and endurance, payload capacity, and onboard processing. Fixed-wing hybrid designs extend loiter time while preserving VTOL agility; however, payload limits constrain which EO/IR packages and radar modules fit without redesign. Autopilot integration and IMU alignment are essential for coherent geolocation across sensors. For teams shopping options, searching for a “fixed wing hybrid vtol drone for sale” narrows models that already balance these constraints. Budget decisions hinge on whether the mission needs high-resolution gimbal imagery or a radar-centric persistent track.
Sensor fusion realities: data flow, latency, and false alarms
Sensor fusion is not simply wiring cameras to a processor. It requires synchronized timestamps, common geospatial references, and calibrated gimbal-to-airframe transforms. Latency across EO, IR, and radar pipelines determines whether the system can cue a weapon, hand off a track, or only record for post-mission analysis. Power and thermal budgets influence which sensors can run simultaneously; heavier radar sweeps and active cooling add weight and drain, cutting loiter time. Teams often underestimate electromagnetic compatibility—radar emissions will affect sensitive IR electronics unless mitigated with shielding and filtering.
Integration pitfalls and operational lessons — small but important
Common mistakes show up in field trials: under-specified mounts that shift gimbal boresight, autopilot firmware that introduces micro-jitters, and insufficient bandwidth between on-board processors and downlinks. These are solvable, but they cost iterations and flight hours. — Plan for calibration flights early, and allocate slots for firmware updates after each hardware change. Interoperability with ground systems—the formats and coordinate datums—matters as much as raw sensor quality.
Real-world anchor: what conflict-driven testing revealed
Deployments in contested environments, notably in Eastern European theaters since 2022, demonstrated two practical points. First, platforms combining EO/IR fusion with modest radar provided mission advantage in contested visibility (smoke, dusk). Second, simpler payloads flown longer often outperformed complex sensor stacks that reduced sortie duration. These outcomes encouraged modular designs: swappable gimbals and plug-in radar pods enable tailoring to a mission without redesigning the whole airframe.
Procurement comparisons and alternatives
Decision-makers should compare like with like: endurance and payload mass versus resolution and sensor frame rate. Consider alternatives that separate functions—smaller VTOL teams for close-in ISR paired with long-range fixed-wing observers—or single hybrid airframes that accept trade-offs for logistics simplicity. Factor in sustainment: spare parts, trained technicians, and the supply chain for specialized gimbal motors and radar modules often decide long-term operational availability more than initial cost.

Three golden rules for selecting EO/IR fusion UAV systems
1) Match loiter time to the mission cadence: choose an airframe whose endurance exceeds the operational sortie profile by at least 25% to allow for contingencies. 2) Insist on documented sensor integration: require calibration procedures, latency budgets, and EM compatibility reports from suppliers. 3) Prioritize modular payloads and open interfaces so upgrades—new algorithms or sensors—reduce lifecycle cost. These metrics cut through marketing claims and reveal what will actually serve operators.
For specifications, comparative reviews, and supplier listings that put these rules into practice, explore resources at Military Hub. –